High-Precision Pose Estimation from Single Portraits: ComfyUI 360 Orbit Node
A new ComfyUI custom node extracts multi-view poses from 360-degree orbit videos, combining 24-viewpoint sdpose estimation and depth correction for Qwen Image 2
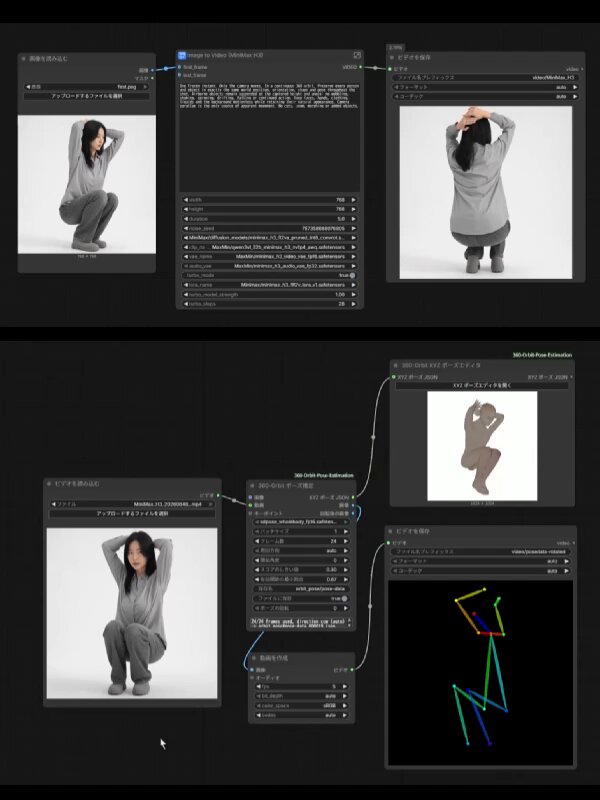
Extracting accurate pose coordinates and skeletal alignment from a single portrait or figure image has long been a labor-intensive challenge in AI image pipelines. On October 5, 2026, AI workflow developer AI Bard Guild (@IsekaiBardGuild) released an open-source ComfyUI custom node and sample workflow (ComfyUI-360-Orbit-Pose-Estimation) that extracts high-precision pose data from 360-degree orbit videos generated around a single portrait.
Image source: @IsekaiBardGuild via X
Rather than attempting to infer occluded poses directly from an isolated static frame, this pipeline leverages a camera orbit around the subject to capture multi-angle perspectives, applying automated depth estimation and coordinate correction. This technique significantly reduces the need for manual pose retouching while providing reliable pose guidance for downstream generation models.
Multi-View Pose Estimation via 360 Orbit Videos and 24 Viewpoint Extraction
Traditional single-view pose estimators frequently struggle with occluded limbs and ambiguous joint depths when analyzing a static 2D image. The newly released workflow bypasses these fundamental ambiguities by employing video generation models as multi-perspective visual samplers.
-
Acquiring the 360-Degree Orbit Video:
- The workflow begins by taking a single source portrait image and generating a 360-degree orbit video rotating around the subject.
- While the developer demonstrated the approach using MiniMax H3 360 Orbit, the pipeline does not strictly depend on MiniMax H3. Any AI video generation model capable of producing a consistent camera turntable, or even clean real-world turntable footage meeting the requirements, can be utilized as the visual source.
-
Extracting 24 Viewpoint Frames:
- By default, the node extracts 24 viewpoint frames across the rotational path for estimation.
- By traversing the orbit, anatomical features that remain hidden in the single frontal angle become visible across multiple viewpoints.
-
sdpose Joint Estimation with Depth and Coordinate Alignment:
- The extracted multi-view images are processed through
sdposeto estimate skeletal landmarks across angles. - The custom node pairs this multi-angle pose estimation with depth estimation and coordinate correction.
- While the developer characterized this methodology as a brute-force approach (力技), they noted that it feels considerably better than having a human manually perform pose correction work.
- The extracted multi-view images are processed through
Custom Node Architecture and Integration with Qwen Image 2.1
The open-source repository (hiderminer/ComfyUI-360-Orbit-Pose-Estimation) packages the multi-step pipeline into ComfyUI building blocks.
-
Included Deliverables:
- The core ComfyUI custom node handling viewpoint extraction,
sdposeinference, depth estimation, and coordinate correction. - A pre-configured sample workflow demonstrating ready-to-run node connections.
- The core ComfyUI custom node handling viewpoint extraction,
-
External Model Dependencies and Prerequisites:
- The repository exclusively contains the custom node code and sample workflow.
- It does not bundle model weights or setup info; users must independently provide checkpoints for MiniMax H3 video generation, Qwen Image 2.1, and any associated LoRA adapters within their local environment.
-
Feeding Downstream Qwen Image 2.1 Workflows:
- The corrected pose outputs connect directly into downstream workflows, such as Qwen Image 2.1 pose-guided pipelines.
Practical Caveats: Stylized Illustrations and Handheld Video Constraints
In technical discussions regarding real-world application, the author highlighted key performance boundaries and operational trade-offs.
-
Default Viewpoint Sampling:
- The custom node extracts and estimates poses from 24 viewpoints by default. When asked how many viewpoints are needed for stability, the developer confirmed that 24 viewpoints is the default setting.
-
Limitations with Stylized Illustrations (sdpose):
- Images that are far from photorealistic, such as stylized illustrations, present significant estimation difficulties.
- The developer clarified that this stems from the characteristics of
sdposerather than MiniMax, noting that using a model specialized for pose recognition from illustrations might make it possible.
-
Handheld Live-Action Video Feasibility:
- When asked whether casual handheld video footage works compared to clean turntable orbits, the author stated that it remains untested ("won't know without trying").
- The author noted that supporting handheld video might require improvements such as acquiring accelerometer data from the camera to compensate for camera motion.
Original source
- AI Bard Guild (@IsekaiBardGuild) on X: ComfyUI 360 Orbit Pose Estimation Workflow Announcement
- GitHub Repository: hiderminer/ComfyUI-360-Orbit-Pose-Estimation