Astra 프롬프트 추출과 MiniMax H3로 구현하는 고난도 메카닉 변신 영상 워크플로우
단순 프롬프트로 실패하기 쉬운 로봇 변신 시퀀스를 Astra로 정밀 디컴파일하고 MiniMax H3의 물리 연속성 프롬프트로 완성하는 제작 팁과 실전 영문 프롬프트 전문.
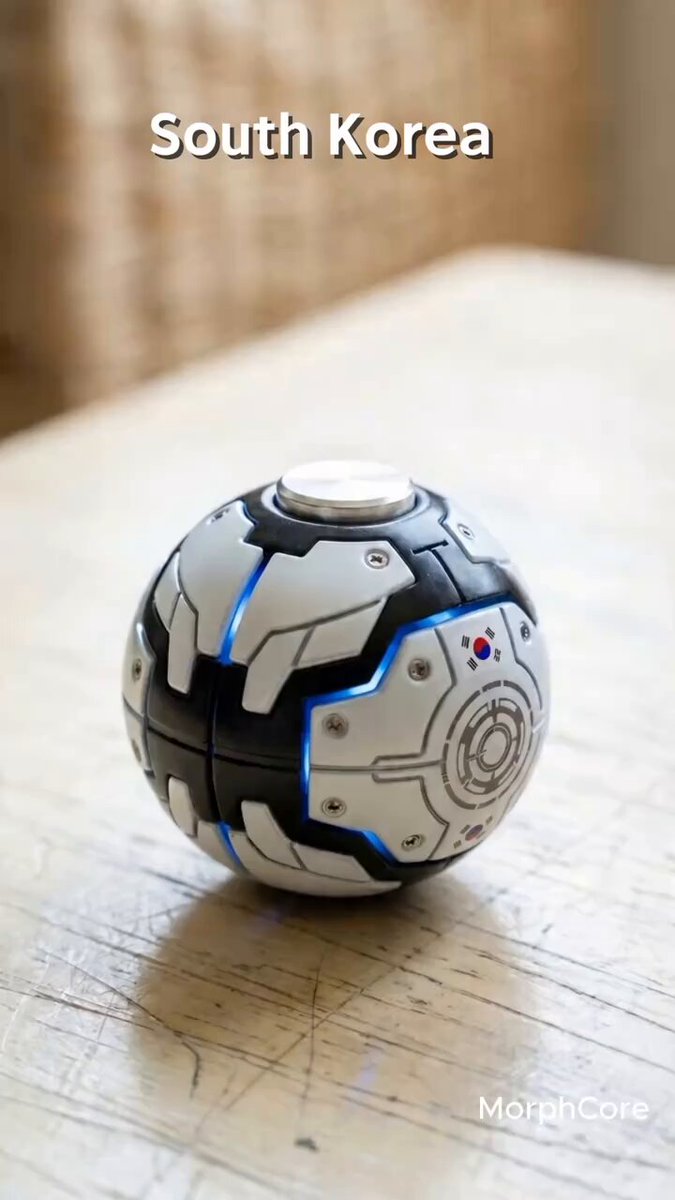
AI 크리에이터 대운(@daeun_lab)이 GPT-6 Astra를 활용한 영상 프롬프트 추출과 MiniMax H3 비디오 생성 모델을 결합해, 생성형 AI 영상 제작에서 난이도가 가장 높은 영역 중 하나인 '로봇 변신(Mechanical Transformation)' 시퀀스를 물리적 연속성을 지닌 모션으로 정밀 구현하는 워크플로우와 실전 프롬프트 전문을 공유했습니다.
이미지 출처: @daeun_lab / @GreatZodd (X)
하나의 닫힌 구 형태 완구가 관절과 장갑판을 차례로 전개하며 네 발로 서는 기계식 백호 로봇으로 변신하는 연속 동작을 단일 샷으로 완성한 사례로, 피사체 구조가 무너지거나 부품이 공중에서 생성·소멸하는 모핑(morphing) 한계를 프롬프트 구조화로 극복한 기법입니다.
메카닉 변신 영상의 생성 한계와 해결 워크플로우
영상 생성 AI에서 기계 장치의 변신이나 정밀 조립 과정은 모델의 시공간 일관성(spatio-temporal consistency)을 시험하는 대표적인 고난도 영역입니다.
크리에이터 조드(@GreatZodd)는 원본 변신 영상을 재현하기 위해 Astra나 Muse로 프롬프트를 추출해 Google Flow 등 일반적인 생성 파이프라인으로 시도했으나, 피사체가 녹아내리듯 변형되거나 부품의 정체성이 훼손되는 품질 저하 문제를 겪으며 커뮤니티에 조언을 구했습니다.
이에 대해 대운(@daeun_lab)은 GPT-6 Astra를 통해 원본 영상의 변신 메커니즘과 부품 전개 순서를 정밀하게 디컴파일(역공학)하여 프롬프트를 추출하고, 이를 MiniMax H3 모델에 입력해 최종 영상을 렌더링하는 2단계 해결 워크플로우를 제시했습니다.
MiniMax H3는 복잡한 물리 상호작용과 기계적 관절 이동, 오디오-비주얼 동기화에 강점을 가진 모델로, 명확한 파츠 정의와 시차적 동작 묘사가 뒷받침될 때 부품의 소실 없이 정교한 변신 궤적을 렌더링할 수 있습니다.
실전 메카닉 변신 비디오 프롬프트 전문
대운 크리에이터가 공개한 MiniMax H3용 영문 프롬프트 전문은 다음과 같습니다. 닫힌 구체(Sphere)에서 백호(White Tiger) 로봇으로 전개되는 전 과정을 초 단위 및 기구학적 인과관계로 서술했습니다.
Setting: A single continuous vertical close-up of a transforming robot toy on a pale wooden table, warm diffused window light, beige curtains. Stationary three-quarter camera. Only the toy occupies the tabletop.
At 0.0 seconds one closed ivory-and-silver mechanical sphere is already resting at the center, fully visible. Its shell has six large curved armor plates joined to a black articulated chassis: two blue-ringed side plates, one flag-marked top plate, one lower-front plate, and two rear plates. These six recognizable plates remain attached and visible as the robot unfolds.
In order: blue seams brighten; the front plate swings under the chin as the tucked silver tiger head lifts out; the blue-ringed plates roll outward into broad shoulders as the folded forelegs reach for the table. While the forepaws descend, the flag-marked top plate slides backward along the extending spine and the rear plates swing around the hips. The hind legs unfold underneath those hip plates as the forepaws take weight. The tail uncurls from between the rear plates while the chest moves forward and the back settles between the shoulders. Each next motion starts while the preceding motion is still in progress: head lifting, shoulders rolling, paws reaching, back extending and hips rising form one connected wave. Visible black hinge arms carry the rigid shell plates through curved paths, leaving the same six plates as substantial armor on the final animal.
The robot leans onto its reaching forepaws, shifts its weight through the shoulders and follows with the hindquarters, like a cat uncurling and standing up. Its joints yield slightly under weight, the tail follows the body's movement with a delay, and the armor plates settle with a small recoil. By the end one compact robotic white tiger stands on four grounded paws with a rounded armored back, broad blue-ringed shoulders and curved hip armor. It holds that stance for the final moment. The entire toy stays visible. Brushed silver, ivory plastic, black joints, blue eyes. Quiet variable-pitch servo whir, soft sliding metal and paw contact, room ambience.
변신 시퀀스를 성공시키는 프롬프트 엔지니어링 5대 핵심 설계 원칙
단순히 "로봇이 백호로 변신한다"는 추상적인 묘사 대신, 인공지능 모델이 기계 부품을 일관된 객체로 추적할 수 있도록 5단계 물리적 닻(Anchor)을 설정했습니다.
1. 환경 및 카메라 고정 (Camera & Environment Anchor)
- 카메라 고정:
Stationary three-quarter camera로 시점을 쿼터 뷰에 단단히 고정했습니다. 카메라가 움직이면서 피사체까지 함께 변형되는 인공지능 특유의 왜곡을 원천 방지합니다. - 단일 피사체 격리: 밝은 목재 테이블 위에 오직 완구 단 하나만 배치(
Only the toy occupies the tabletop)하여 배경 노이즈로 인한 연산 분산을 차단했습니다.
2. 초기 상태의 부품 목록 선언 (Explicit Initial Part Inventory at 0.0s)
- 변신이 시작되기 전인 0.0초 시점에 구체를 구성하는 6개의 외장 장갑판(
two blue-ringed side plates, one flag-marked top plate, one lower-front plate, and two rear plates)을 명시적으로 열거했습니다. - "이 6개의 식별 가능한 플레이트가 변신 중에도 계속 부착되어 보인다(
These six recognizable plates remain attached and visible as the robot unfolds)"는 보존 규칙을 주입해 부품이 중간에 증발하거나 형태가 뭉개지는 현상을 방지했습니다.
3. 시차적 연쇄 동작과 기계식 힌지 궤적 (Continuous Kinetic Overlap & Hinge Paths)
- 동작을 독립적인 단계로 끊지 않고, 앞선 동작이 끝나기 전에 다음 동작이 시작되는 연결된 파동(
Each next motion starts while the preceding motion is still in progress... form one connected wave) 구조로 서술했습니다. - 파츠들이 허공에 떠서 이동하는 것이 아니라, 검은색 관절 힌지 암(
Visible black hinge arms)이 장갑판을 곡선 궤적으로 지탱하며 이동시킨다는 기계적 연결성을 명시했습니다.
4. 생물학적 하중 이동과 물리적 완충 묘사 (Weight Dynamics & Organic Physics)
- 기계적인 움직임에 고양이가 기지개를 켜며 일어나는 듯한 체중 이동(
like a cat uncurling and standing up)을 결합했습니다. - 바닥에 발이 닿을 때 관절이 하중에 눌리는 미세한 굴절(
joints yield slightly under weight), 몸체보다 늦게 따라오는 꼬리의 2차 동작(delayed tail movement), 장갑판이 최종 위치에 안착할 때의 미세한 반동(small recoil)을 기술해 물리적 무게감을 부여했습니다.
5. 재질 디테일과 다감각 오디오 스케이프 (Materials & Diegetic Soundscape)
- 브러시드 실버, 아이보리 플라스틱, 블랙 조인트, 블루 아이 등 외관 재질과 색상을 일관되게 고정했습니다.
- MiniMax H3의 네이티브 오디오 생성 성능을 활용할 수 있도록, 가변 피치 서보 모터 구동음(
Quiet variable-pitch servo whir), 부드러운 금속 슬라이딩 및 발바닥 접촉음, 실내 공간 앰비언스를 함께 명시했습니다.
실무 비디오 디렉팅 적용 팁
- Astra 비디오 디컴파일 활용: 복잡한 움직임이나 변신 기구를 가진 레퍼런스 영상이 있다면, GPT-6 Astra에게 장면을 프레임 단위로 분석시켜 부품의 공간 배치와 동작 순서를 기구학적 언어로 번역하도록 요청합니다.
- 시공간 연속성이 강한 백엔드 엔진 선택: 정밀한 다단계 메카닉 모션은 단순 확산 모델보다 물리 연속성 해석 능력이 뛰어난 MiniMax H3 등의 전용 비디오 생성 모델을 채택할 때 최상의 결과를 얻을 수 있습니다.
- 카메라 움직임 최소화: 피사체 내부의 형태 변화가 극심한 씬에서는 역동적인 카메라 무빙을 지양하고, 카메라를 고정한 채 피사체의 기계적 궤적에 모델의 연산력을 집중시키는 것이 성공률을 높이는 핵심입니다.
원문 출처
- 대운 (@daeun_lab) 및 조드 (@GreatZodd) X 원문 스레드: Astra 프롬프트 추출과 H3 메카닉 변신 영상 워크플로우